One Week to RES: The Right Model, in the Right Place
Preparing for SICK’s Robotics Exchange Summit with a practical question: how can omnimodal AI, open weight models, and the right tools help robotics workflows work better?
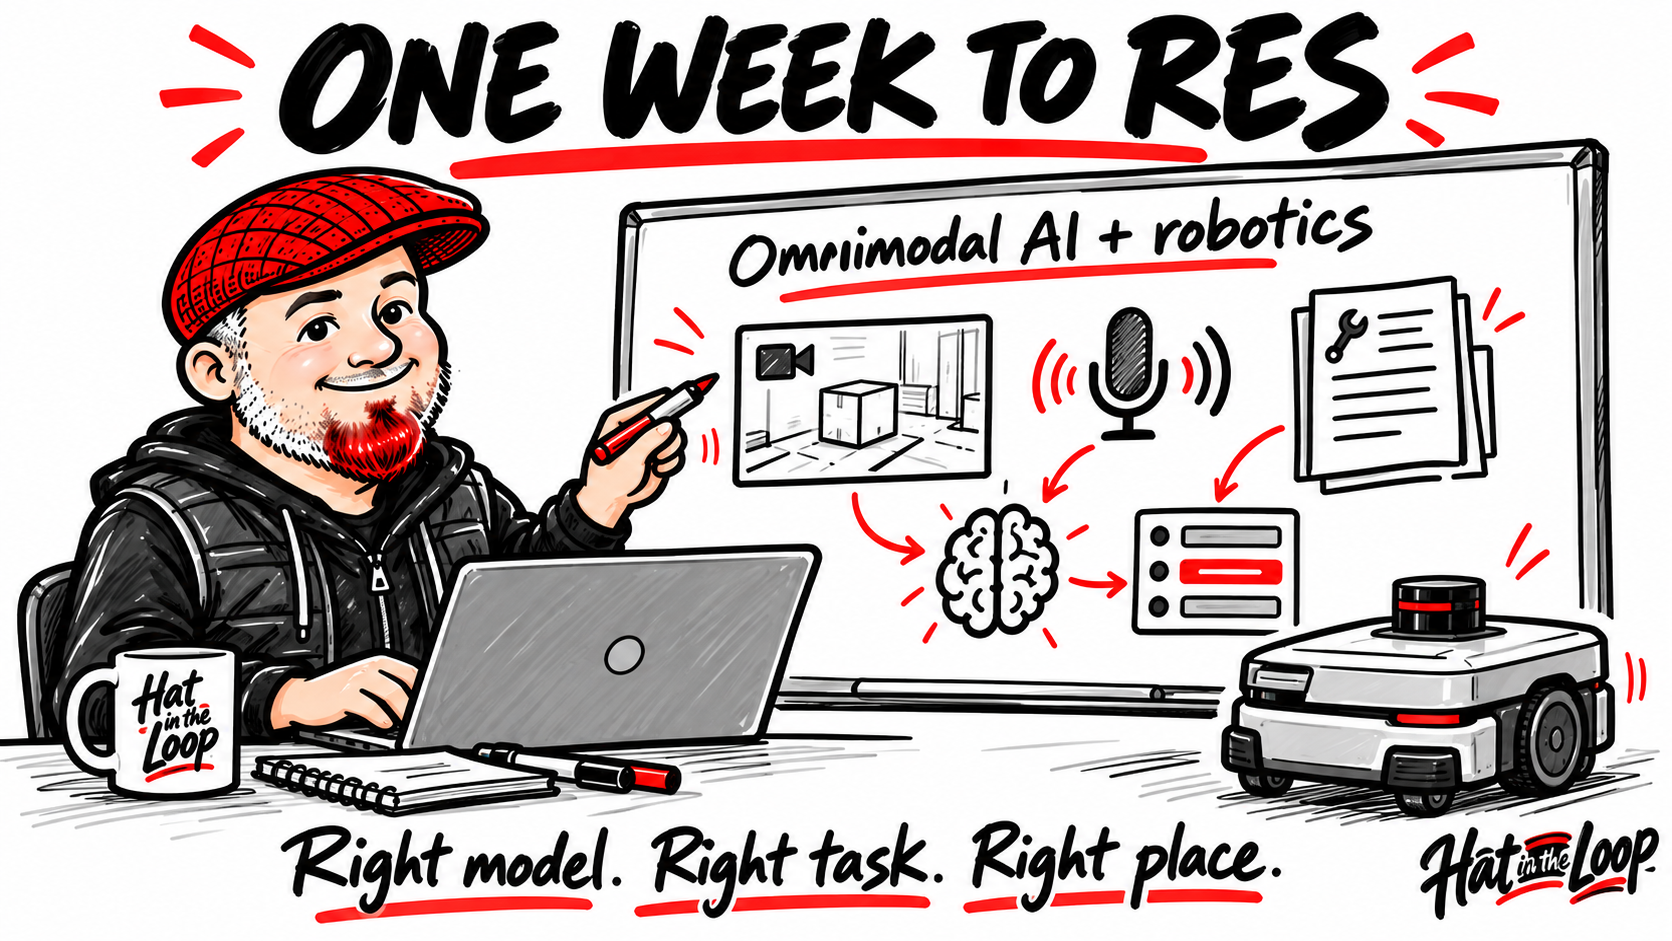
We’re one week away from the Robotics Exchange Summit, hosted by SICK, and I’m sitting down to build my slide deck.
Yes... slides. I normally prefer showing something people can interact with. But I have a few ideas I want to work through with this group.
I spend a lot of time talking about product safety, training, education, and agentic AI. Those topics are coming with me. This time, I’m bringing them into the world of robotics and mobile robotics.
One idea I’m especially interested in is omnimodal AI: working across text, images, audio, and video.
Think about a mobile robot that keeps stopping in the same area. A technician has a video of what happened. An operator explains what they saw. The equipment logs and service documentation add another part of the story.
I want to explore how AI could bring those pieces together and help a person decide what to check next.
Then comes the workflow question: which model or tool should handle each part of that job?
A smaller model might handle a routine task. A more capable model might be worth using for a difficult case. An agent could retrieve the relevant records, coordinate the tools, and prepare the findings for someone to review.
That’s also why I’m interested in open weight models. Depending on the model, its license, and the hardware, they give us options for running capabilities locally and choosing where the work happens. We still have to test whether those choices improve quality, response time, and total cost.
The right model. The right task. The right place in the workflow.
For me, that connects directly to the operator experience, technician support, and how we teach people to use these systems. Getting useful information to someone in a form they can actually use is a big part of making the technology work.
Thank you to the folks at SICK, the RES team, and Mark Kennedy for bringing this group together and including me. I’m looking forward to sharing these ideas and hearing what people building and deploying robots think.
October 5–7. One week to go.
If you’ll be there, look for the guy in the hat.
Originally posted on s.sick.com. Join the conversation there.